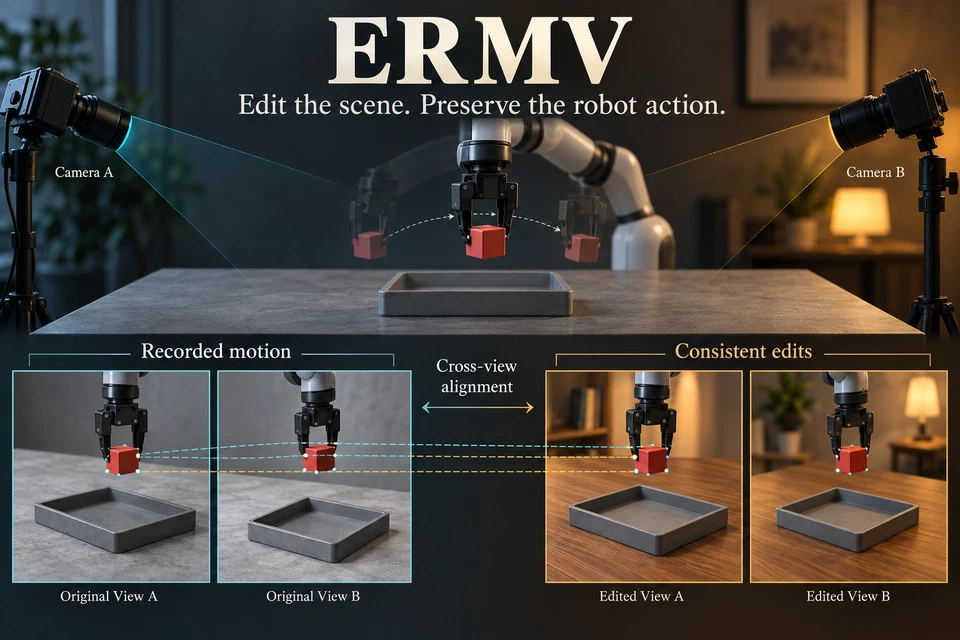
ERMV: Editing 4D Robotic Multi-view images to enhance embodied agents
A 4D multi-view generative world model for robot demonstration augmentation, editing spatiotemporal appearances while strictly preserving recorded physical actions for downstream VLA policies.
Read paper story