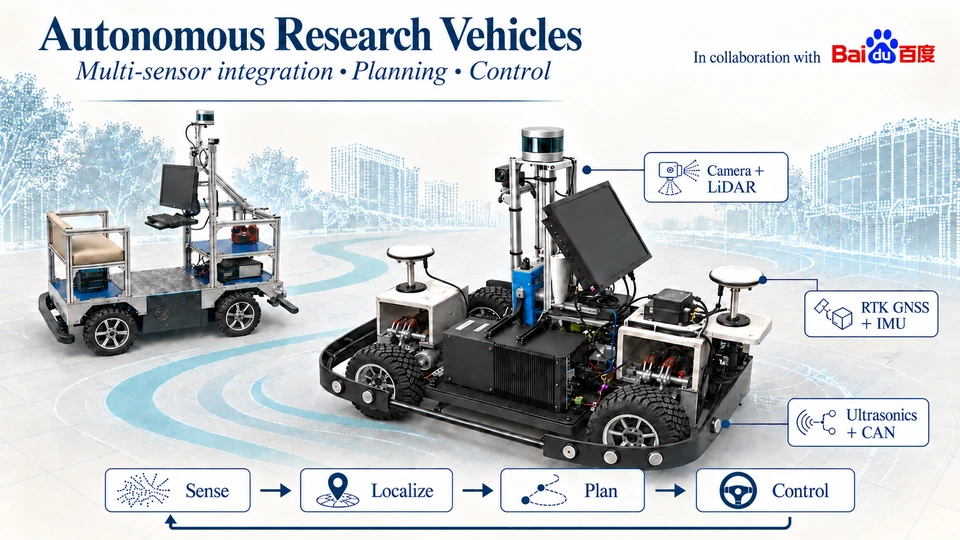
Full-Stack Autonomous Driving Research Platform: Hardware-Software Co-Design & Real-Vehicle Verification
Passenger-vehicle and four-wheel independent-steering AGV platforms integrate perception, localization, planning, and control for low-speed autonomous driving research.
View project