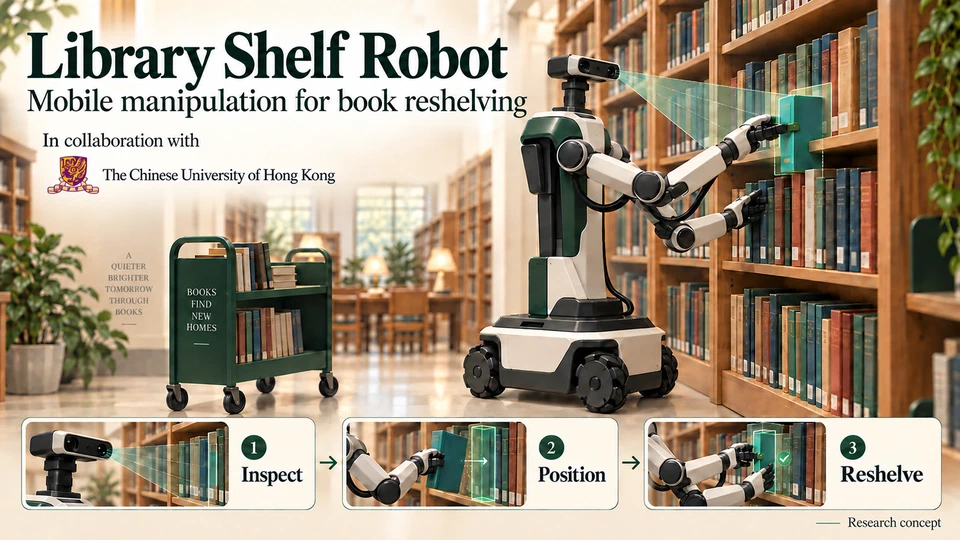
CUHK Collaboration: Mobile Dual-Arm Manipulation for Library Shelf Tidying and Book Reshelving
This project investigates mobile dual-arm manipulation with object perception and task planning for autonomous book retrieval, placement, and shelf organization.
View project