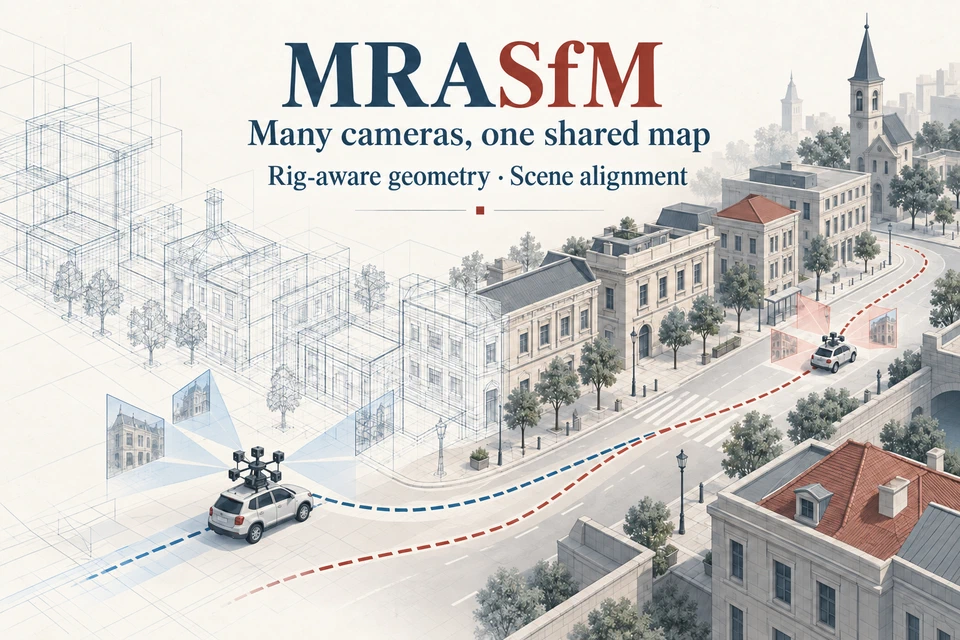
MRASfM: Multi-Camera Reconstruction and Aggregation through Structure-from-Motion in Driving Scenes
Adapts multi-camera Structure-from-Motion to autonomous driving scenes, combining rigid multi-camera geometry, road-surface filtering, and multi-run spatiotemporal map aggregation.
Read paper story