Featured Engineering Projects & Systems
Covering mobile dual-arm manipulation for biochemical labs, industrial logistics tote unstacking, automotive 4D auto-annotation, autonomous valet parking (AVP), and commercial robotic mowers. Documenting full-stack engineering across system architecture, multimodal calibration, algorithm development, and real-robot deployment.
 Dual-Arm Manipulation · Embodied Policy
2026
Dexterous Manipulation
Validated
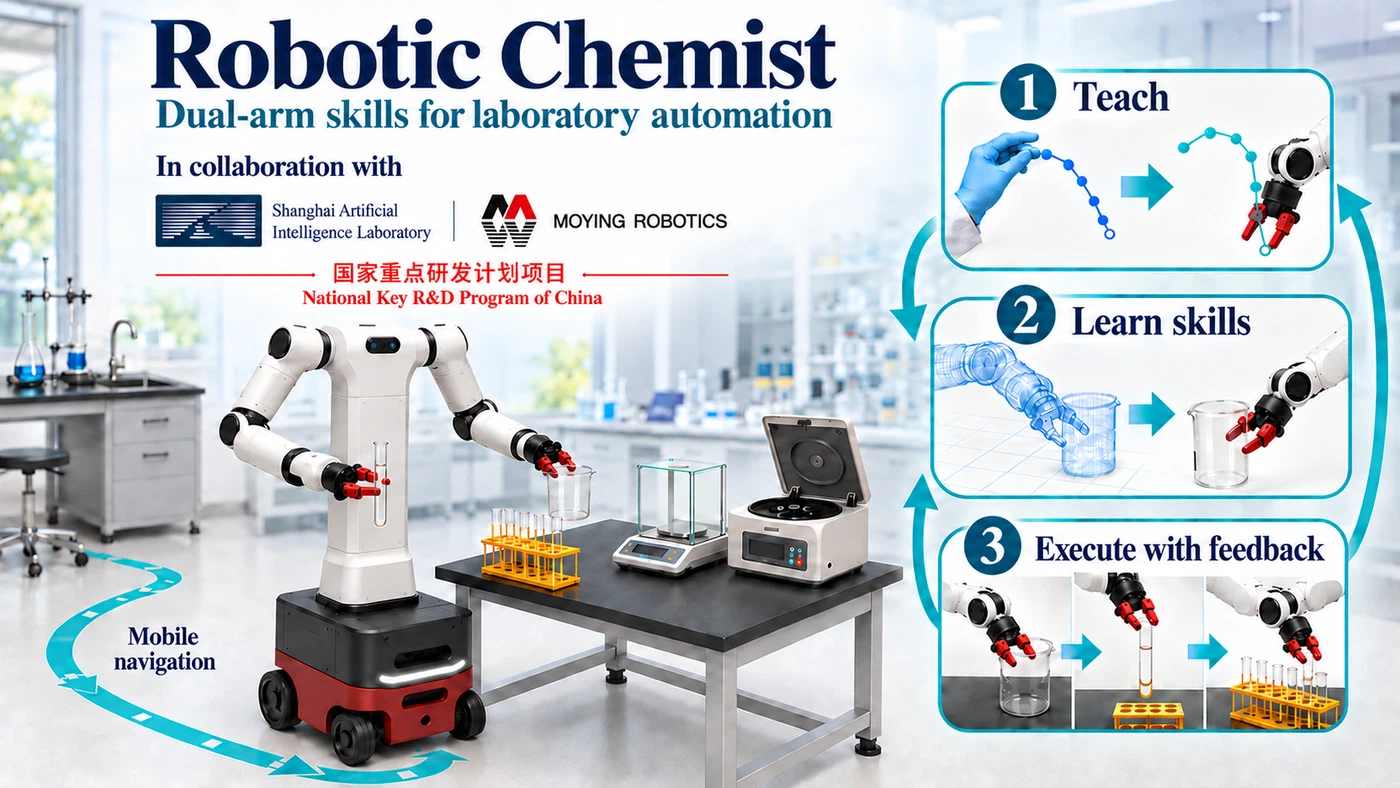
A mobile dual-arm robotics system combines perception, skill learning, and task planning to automate multistep chemistry laboratory operations.
Project Overview
- Full-Stack Architecture
- Autonomous mobile navigation, multimodal 3D perception, coordinated dual-arm manipulation, demonstration retargeting, few-shot skill learning, and LLM/VLM hierarchical planning
- My Work on This Project
- Led a 10-person team architecting the full-stack mobile dual-arm chemistry system; directed VLA fine-tuning and edge deployment, collecting 100+ hours of physical data and 10,000+ simulation trajectories, achieving 92%+ end-to-end task success.
- Key Deliverables & Verification
- Autonomous full-protocol physical chemistry trials, high-precision centrifuge loading, transparent labware 6D pose recovery, smooth fluid transport, and hierarchical self-healing execution
 Skill Planning · Mobile Manipulation
2026
Skill Planning
In Progress
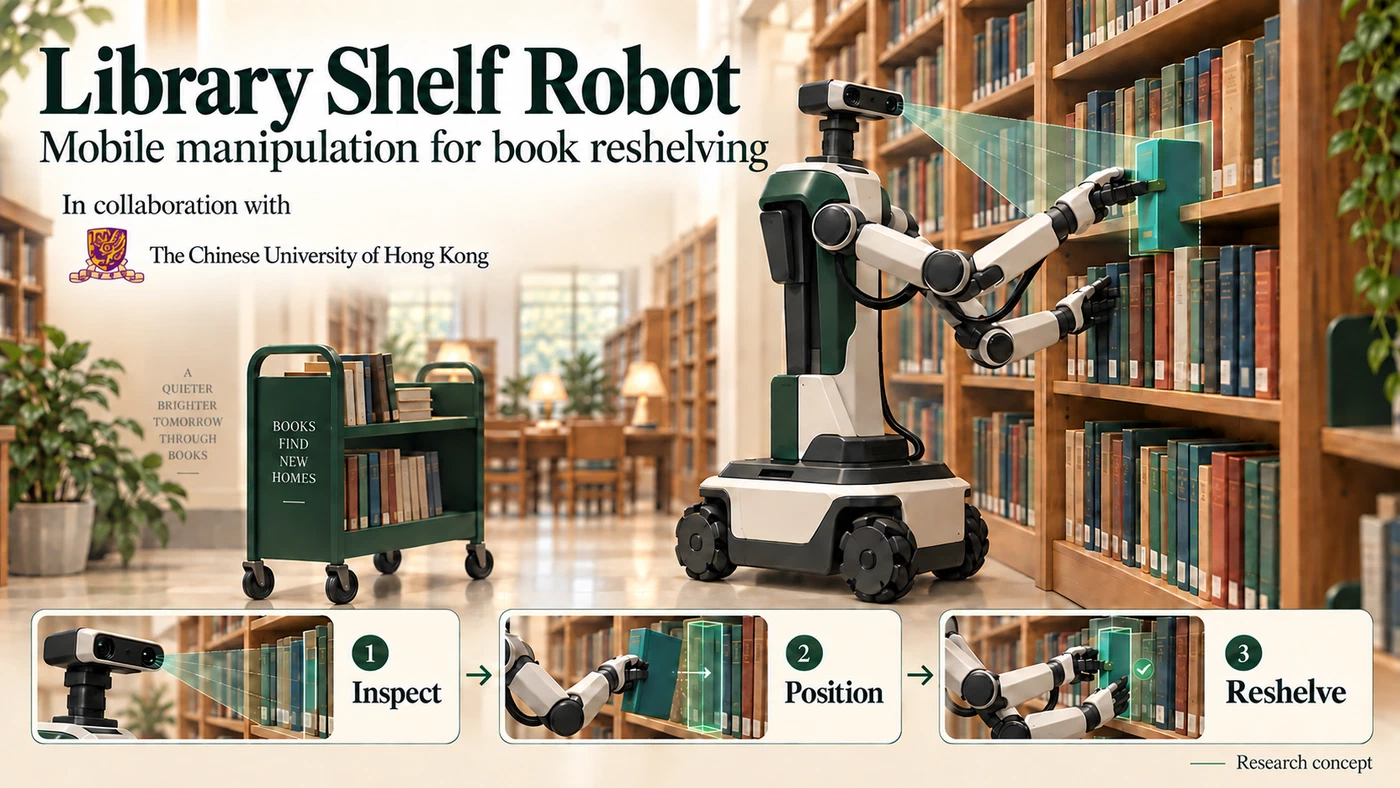
This project investigates mobile dual-arm manipulation with object perception and task planning for autonomous book retrieval, placement, and shelf organization.
Project Overview
- Full-Stack Architecture
- AI Agent orchestration, object-centred world model, mobile dual-arm coordinated control, and sim-to-real transfer
- My Work on This Project
- As project lead, established the mobile dual-arm manipulation framework; responsible for coaxial visual servoing and closed-loop agent execution, setting research targets for bimanual extraction (>92% success rate) and jammed slot recovery (>80% recovery rate) in 1.5–3.0 mm tight shelf clearances.
- Projected Goals & Research Focus
- End-to-end workflow for dense shelf extraction and millimeter slot insertion; targeting >92% bimanual extraction success and >80% jam recovery success in anticipated hardware deployment.
 Hierarchical Planning · Multimodal Perception
2026
Task Planning
In Progress
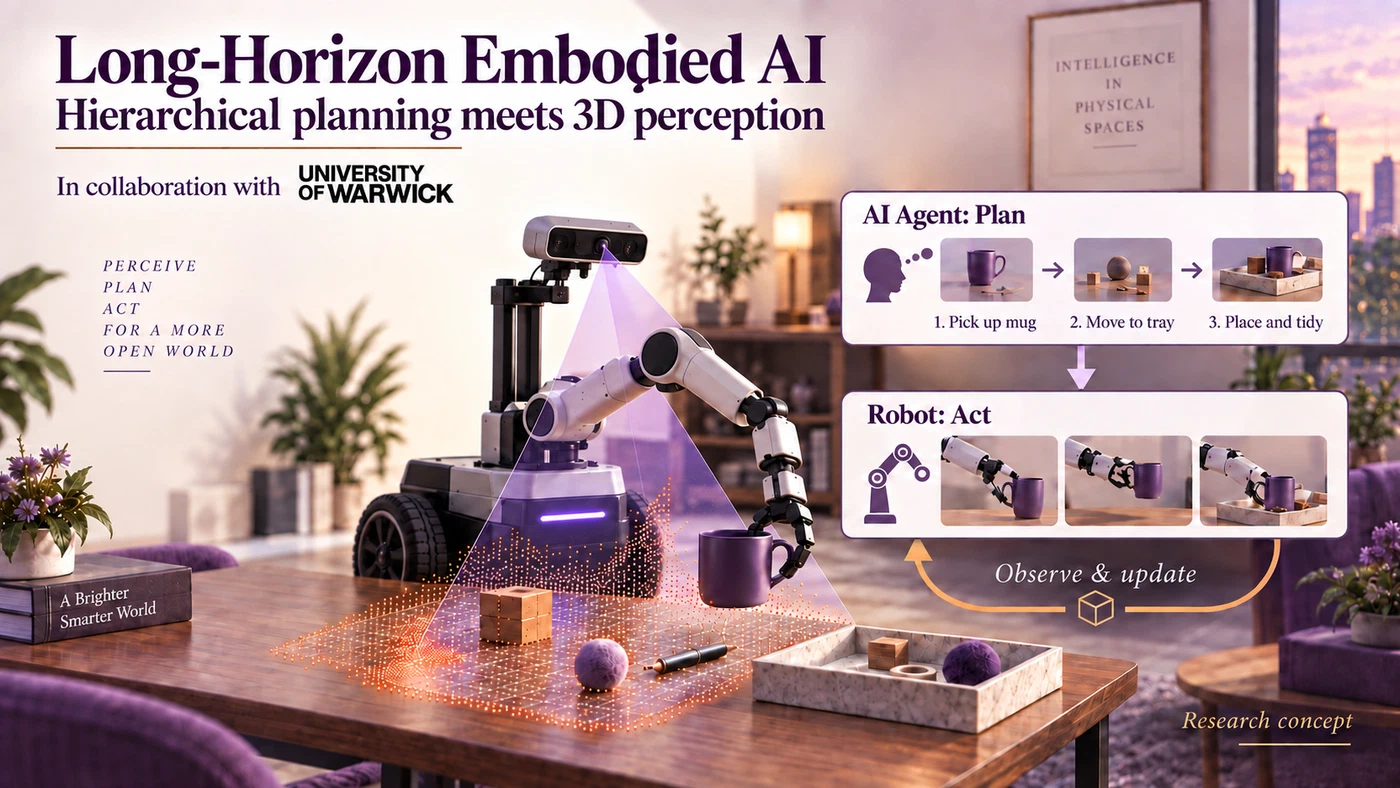
This collaboration explores multimodal 3D perception and hierarchical planning to connect high-level task instructions with closed-loop robot control.
Project Overview
- Full-Stack Architecture
- Multimodal 3D perception, high-level task planning, low-level robot control, and closed-loop execution
- My Work on This Project
- As project lead, formulated the hierarchical agent manipulation architecture; for 8–15 step long-horizon tasks, established target objectives to elevate end-to-end task success rate from 35% to >84%, with >70% autonomous recovery from localized physical anomalies.
- Projected Objectives & Research Focus
- Closed-loop 8–15 step physical embodied manipulation; targeting >84% end-to-end success, >70% localized recovery, and <3 mm 3D localization error under multimodal fusion.
 6D Pose Estimation · Dual-Arm Control
2025
Dual-Arm Control
Deployed
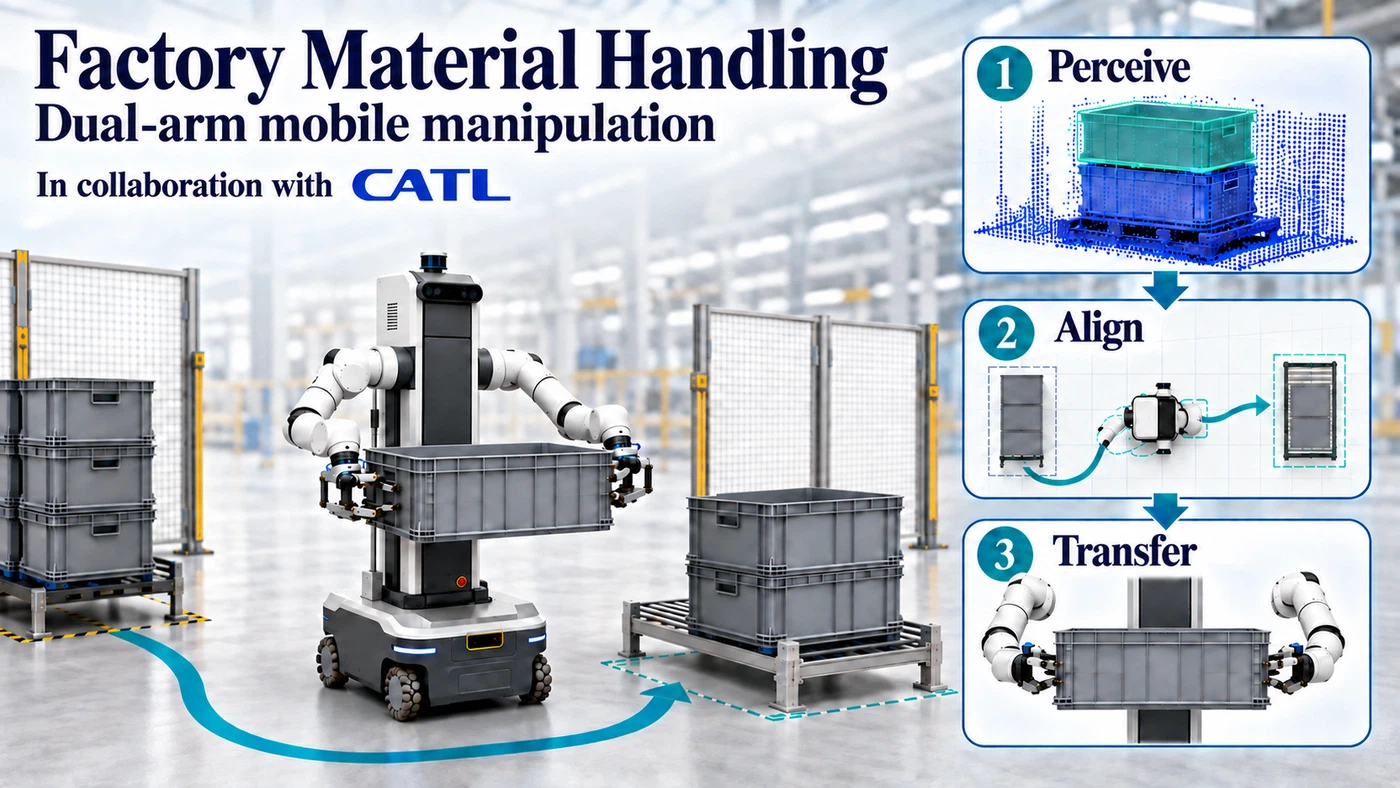
A mobile dual-arm robot combines 3D vision, navigation, and coordinated manipulation to unstack and transfer material totes between factory stations.
Project Overview
- Full-Stack Architecture
- 3D vision pose estimation, autonomous navigation, dual-arm coordinated unstacking, adaptive tote transfer, and closed-loop execution
- My Work on This Project
- Orchestrated the heavy industrial mobile manipulation system; combined VLM perception and 6D pose estimation for 10 kg bimanual payload handling, achieving 98%+ tote unstacking and docking success for high-frequency station transfer.
- Key Deliverables & Real-World Validation
- Bimanual 10 kg payload handling, high-accuracy 3D tote pose estimation (98%+ unstacking success), closed-kinematic-chain impedance decoupling, and robust inter-station transfer
 Multi-Camera SfM · Scene Aggregation
2024
Multi-Camera SfM
Deployed
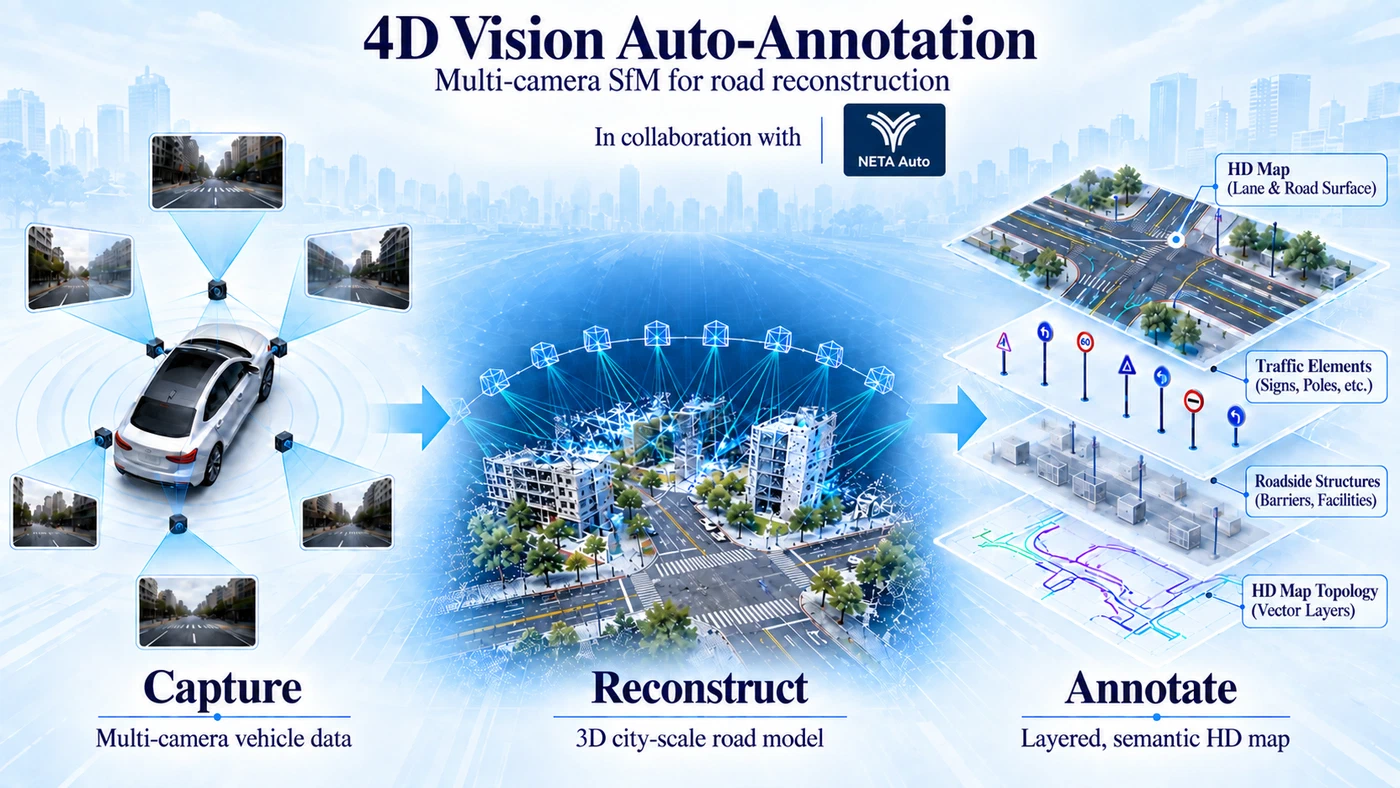
A 4D vision auto-annotation system combines multi-camera 3D reconstruction and multi-run scene aggregation to generate road-element annotations from driving data.
Project Overview
- Full-Stack Architecture
- Spatiotemporal data sync, surround semantic segmentation, multi-sensor localization, multi-camera rig SfM, dense ground reconstruction, automatic road element labeling, and multi-run scene aggregation
- My Work on This Project
- Led a 5-person algorithm team engineering the multi-camera 3D reconstruction and 4D annotation pipeline; processed 1,000+ km multi-run fleet data with sub-5 cm cross-run spatial alignment, boosting annotation efficiency by over 80%.
- Production Deliverables & Automotive Validation
- Automotive 4D auto-annotation production pipeline; processed 1,000+ km fleet data (sub-5 cm cross-run registration), online extrinsic self-calibration, and 80%+ labeling efficiency gain
 Sensor Fusion · Motion Planning & Control
2024
Planning & Control
Deployed
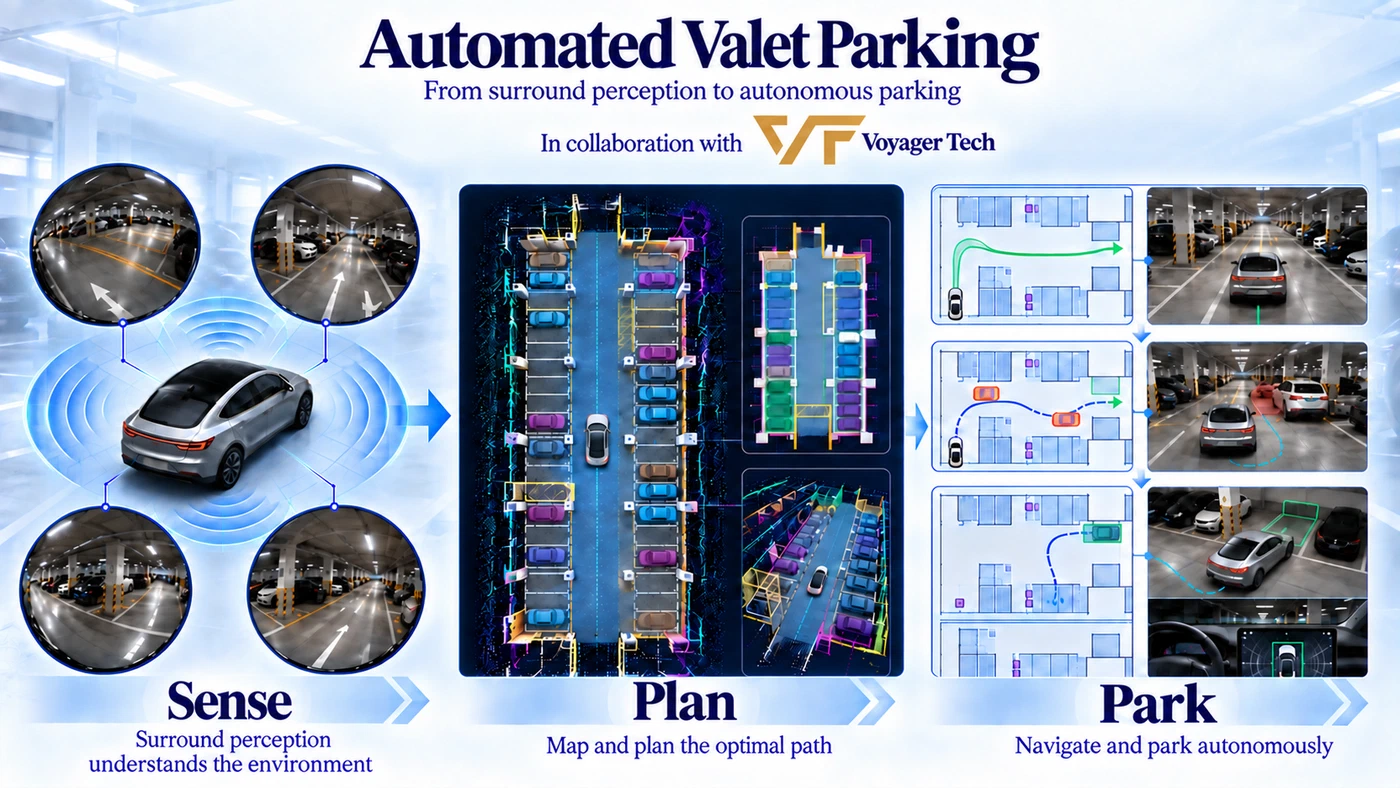
An automated valet parking system combines surround-view perception, localization, planning, and vehicle control for autonomous driving and parking in garages.
Project Overview
- Full-Stack Architecture
- User HMI, surround fisheye/ultrasonic perception, multi-sensor fusion localization, BEV semantic mapping, driving & parking planning, dynamic chassis control, and remote summon
- My Work on This Project
- As project lead, architected the full-stack AVP system framework; directed planning and control under GNSS denial, completing 500+ in-vehicle road tests with 95%+ parking success.
- Core Deliverables & Real-World Validation
- Automotive pure-onboard AVP system; 500+ in-vehicle road tests (95%+ parking success), GNSS-denied multi-sensor localization, narrow-slot maneuvering, and remote summoning
 Terrain Modeling · Multimodal Obstacle Detection
2023
Terrain Perception
Commercialized
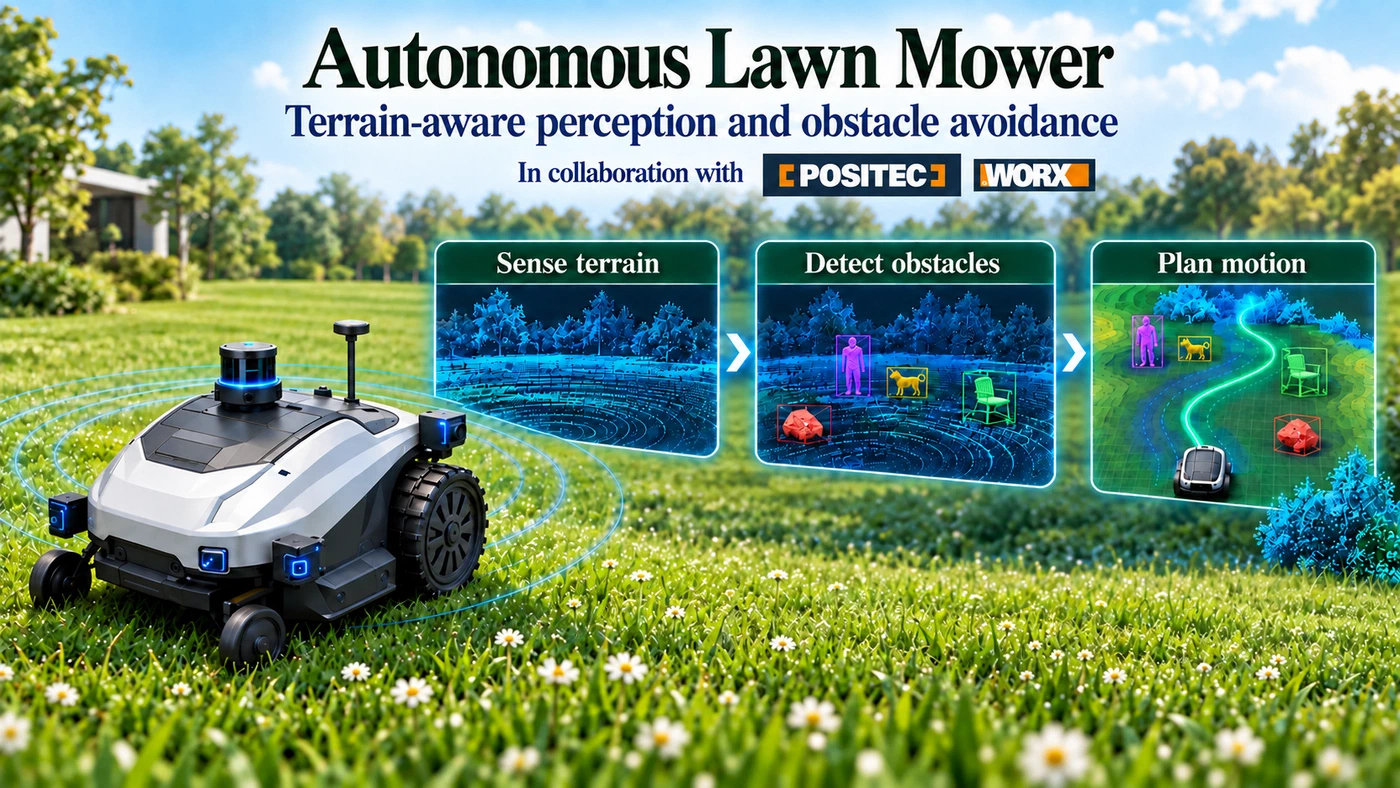
An outdoor mowing robot combines terrain and obstacle perception, multisensor localization, and coverage planning for autonomous lawn maintenance.
Project Overview
- Full-Stack Architecture
- Multi-camera, RGB-D, LiDAR, RTK/GNSS, IMU, wheel odometry, embedded GPU, factor-graph localization, coverage planning, and closed-loop actuation
- My Work on This Project
- As project lead, developed slope-adaptive LiDAR point-cloud filtering and visual obstacle avoidance for Positec robotic lawn mowers, achieving >98% obstacle avoidance success rate and resolving point-cloud clutter filtering, positive/negative obstacle separation, and multimodal sensor fusion on rolling terrain.
- Key Deliverables & Field Validation
- Commercial-grade integrated robotic hardware-software system; >98% obstacle avoidance success rate, terrain-adaptive 3D obstacle perception engine, positive/negative obstacle extraction, and field-proven autonomous mowing
 Drive-by-Wire Control · Sensor Integration
2022
Sensor Integration
Deployed
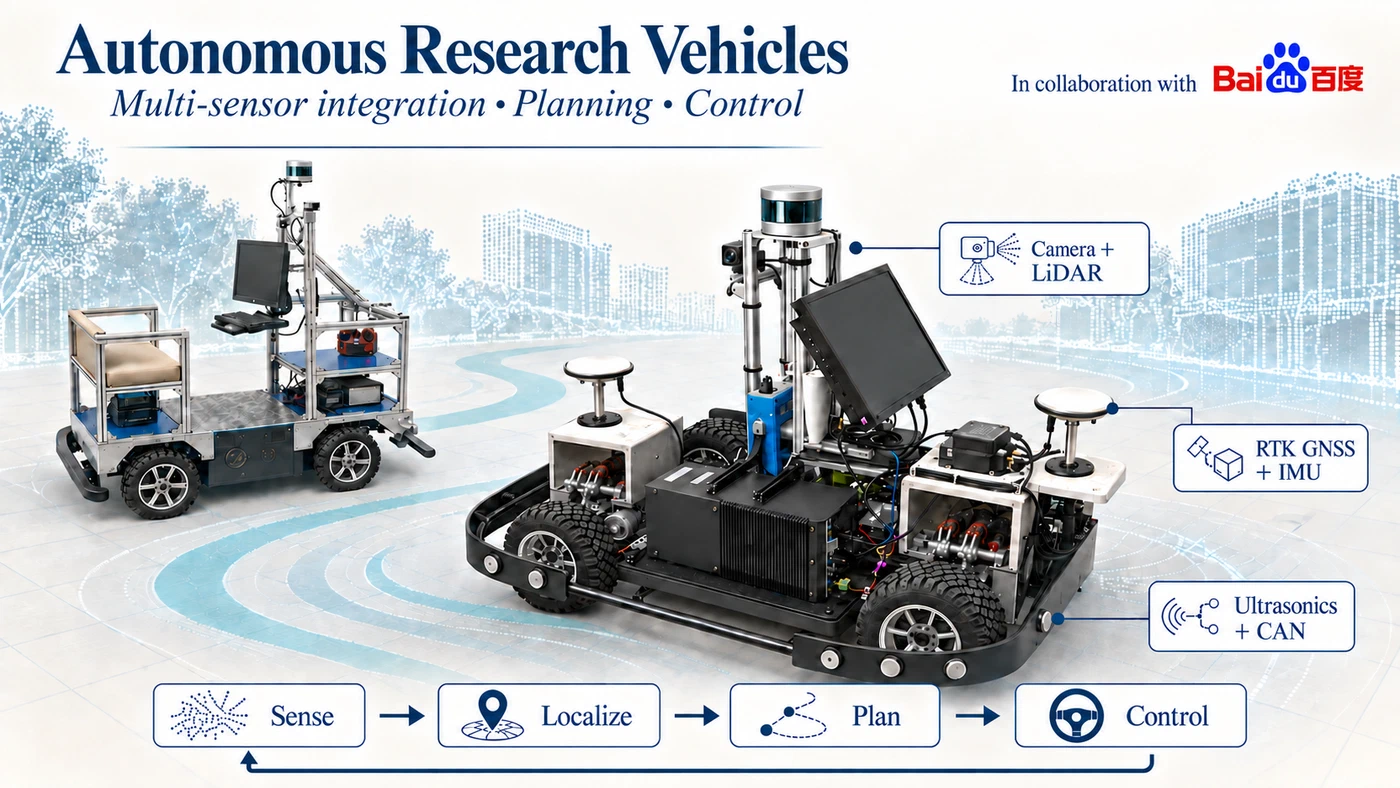
Passenger-vehicle and four-wheel independent-steering AGV platforms integrate perception, localization, planning, and control for low-speed autonomous driving research.
Project Overview
- Full-Stack Architecture
- Spatiotemporal multi-sensor acquisition, 3D perception, HD LiDAR mapping & RTK positioning, hierarchical planning, CAN actuation, and V2X multi-vehicle platooning
- My Work on This Project
- As project lead, built two generations of drive-by-wire autonomous vehicle research platforms (passenger cart and 4WIS AGV) from scratch, accumulating 300+ hours of physical road testing; responsible for drive-by-wire modification, power isolation, CAN bus reverse engineering, and multi-scenario closed-loop validation.
- Platform Deliverables & Multi-Scenario Real-Vehicle Demonstrations
- Two operational drive-by-wire autonomous research platforms; 300+ hours of road testing, 8 real-vehicle closed-loop demonstrations (<5 cm lateral tracking error, <60 ms AEB braking response), and a complete custom ROS autonomy stack.