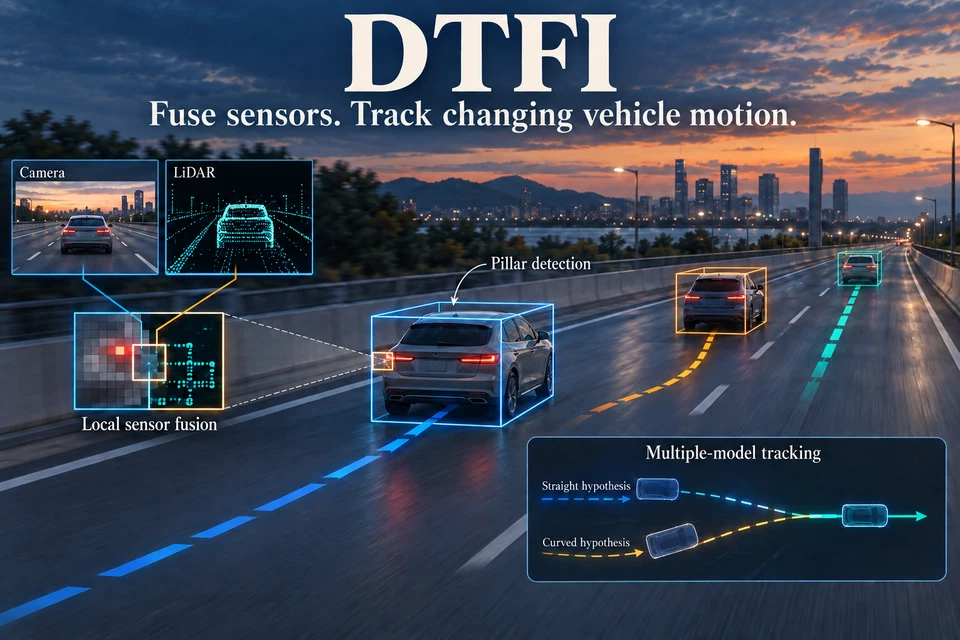
3D Object Detection and Tracking Based on Lidar-Camera Fusion and IMM-UKF Algorithm Towards Highway Driving
DTFI combines local LiDAR-camera feature fusion with IMM-UKF multiple-model filtering for 3D vehicle detection and tracking in highway driving.
Read paper story