Author archive

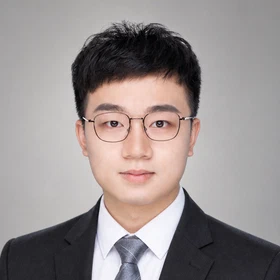
Chang Nie

Ph.D. Researcher (Final Year)

I am Chang Nie (聂畅), a final-year Ph.D. candidate in Control Science and Engineering at the School of Automation and Intelligent Sensing, Shanghai Jiao Tong University, advised by Prof. Hesheng Wang. I expect to defend my thesis in January 2027.

My research focuses on Embodied AI, VLM & LLM foundation models, and Robot Learning, specializing in end-to-end robot policies (VLA, WAM), VLM/LLM cognitive reasoning for robotics, AI Agent manipulation architectures, generative world models, and 3D perception, with physical robot deployment. Experienced in full-stack mobile dual-arm system integration and real-robot manipulation. Dedicated to driving closed-loop deployment of embodied foundation models (VLM/LLM/VLA), AI agents, and generative world models in physical environments.

On this site

Authored works

11 results